 WayForge
Plan, task and deploy uncrewed systems, as one workflow.
WayForge provides a common software layer for planning, tasking and deploying uncrewed systems, supporting repeatable mission design, route control and platform coordination across land, air and maritime environments.
What it does
System behaviour
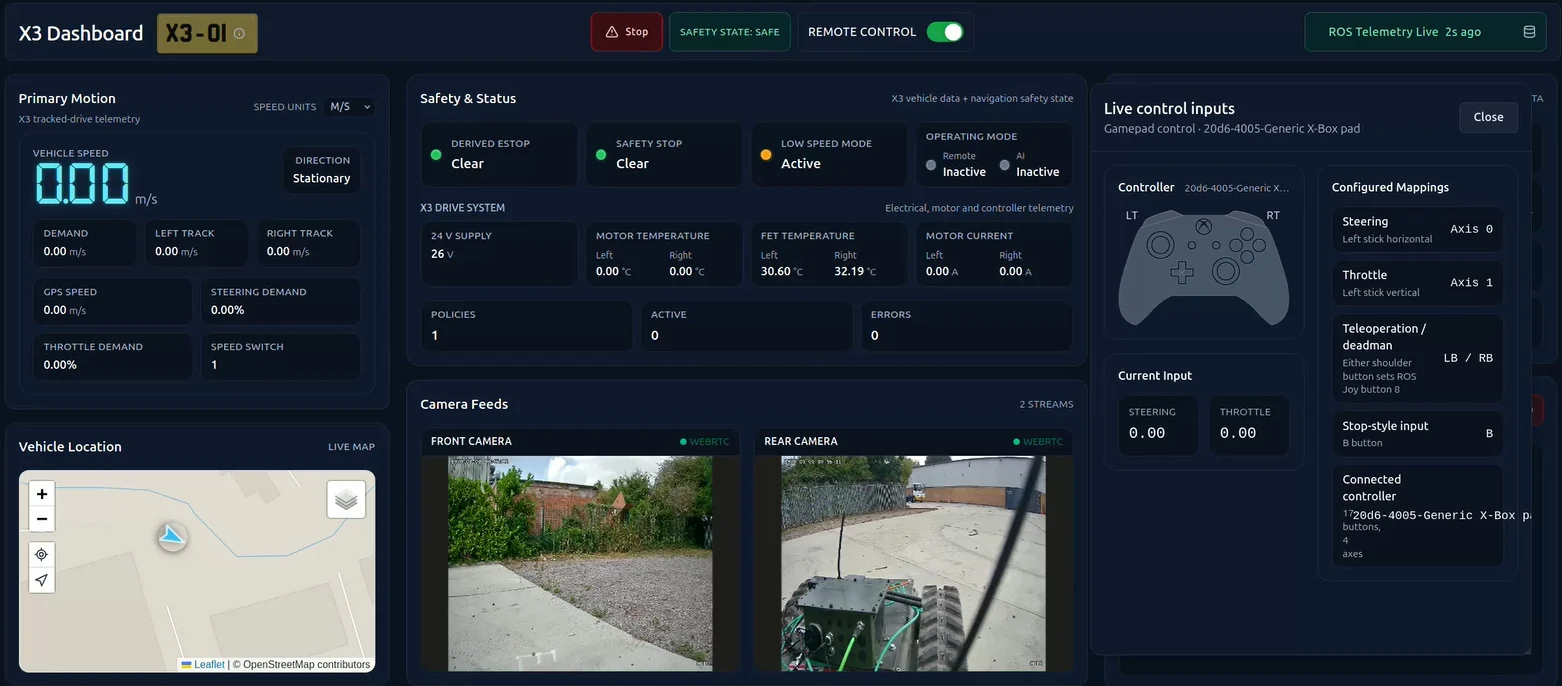
WayForge provides a common software layer for planning, tasking and deploying uncrewed systems. It supports repeatable mission design, route control and platform coordination across land, air and maritime environments, reducing dependence on isolated vendor interfaces. Within Consilium, operators plan missions on a map, draw and validate private road networks, and drive vehicles such as the X3 tracked UGV with live telemetry, safety state and camera feeds. It can operate independently or integrate with Consilium and wider command systems.
Position in the ecosystem: Deploy WayForge as a standalone mission-planning capability, or as the tasking layer across the wider Espanaro solution set.
Three principles
The principles behind WayForge
Plan
Create routes, tasks, waypoints, operating zones and mission constraints.
Deploy
Task and control integrated platforms from secure operational environments.
Integrate
Connect multiple platform types with command systems, sensors and operational data.
The challenge
Defence, national security and critical-infrastructure operators increasingly rely on uncrewed systems, but planning and deploying them often requires separate vendor tools, specialist interfaces and manual coordination.
This creates fragmented workflows, limits interoperability and makes it harder to manage missions consistently across different platforms, environments and operating locations.
Operational value
WayForge delivers:
- Common mission workflow
- Platform interoperability
- Repeatable deployment
- Reduced operator burden
- Faster mission preparation
WayForge provides a hardware-agnostic mission planning, tasking and deployment layer for uncrewed systems, letting operators define routes, tasks, operating constraints and mission objectives from a command post, vehicle or secure control environment, and connect platform activity with the broader operational picture.
Architecture
How it works
WayForge works in four steps, from plan to recover.
- 01PlanRoutes, tasks and zones
- 02TaskPlatform-specific commands
- 03DeployLaunch and control
- 04RecoverReturn and contingency
Core capabilities
Four building blocks for uncrewed-system missions
Mission Planning
Define routes, waypoints, tasks, objectives, operating zones and mission constraints.
Platform Tasking
Translate operator intent into platform-specific commands through controlled integrations.
Mission Execution
Monitor progress, update tasks and manage return, recovery or contingency actions.
Multi-Platform Integration
Provide a common workflow across different vehicles, payloads and vendor ecosystems.
Solution in action
See WayForge working
WayForge plans missions and road networks, and drives uncrewed vehicles, from within Consilium. These screens come from an Espanaro demonstration and test environment.
Vehicles, missions and road networks shown are from demonstration and test environments. Each integration is configured to the vehicles and payloads in use.
Use cases
Where WayForge makes the difference
Secure-Site Patrol
Plan repeatable patrol routes for UGVs around nuclear, defence, airfield and critical-infrastructure sites.
Perimeter & Interdiction
Task platforms to investigate alarms, inspect areas and support controlled security responses.
Reconnaissance & Surveillance
Plan routes and payload tasks for persistent or targeted collection missions.
Hazardous-Area Operations
Deploy platforms into locations where risk, contamination or access constraints limit personnel.
Mission Rehearsal & Trials
Design, repeat and evaluate missions within controlled test and experimentation environments.
Multi-Domain Coordination
Coordinate compatible land, air and maritime assets through a common planning approach.
Integration and deployment
Works with the systems you already run
WayForge provides a hardware-agnostic mission planning, tasking and deployment layer for uncrewed systems. It lets operators define routes, tasks, operating constraints and objectives from a command post, vehicle or secure control environment, and can operate independently or integrate with Consilium and wider command systems.
| Integration area | Supported approach |
|---|---|
| Uncrewed platforms | Integrate with UGVs, UAVs, USVs and other compatible land, air and maritime systems. |
| Sensors & payloads | Incorporate platform telemetry, cameras, sensors and mission payload status into the workflow. |
| Command-and-control systems | Connect mission plans, tasking and platform status with Consilium or third-party command environments. |
| Communications & interfaces | Use platform APIs, messaging services, adapters and approved control interfaces. |
| Espanaro solutions | Integrate with Consilium for the wider operational picture and other Espanaro solutions where mission needs require. |
Delivered with Espanaro
A common uncrewed-systems workflow, built in the UK
Supported by Espanaro capability
The engineering teams behind WayForge also support its integration, deployment and operation.
How to engage
- 1Integration Assessment
Understand the platforms, environments and command systems the mission relies on.
- 2Mission-Planning Workshop
Shape routes, tasking and operating constraints around your platforms and mission.
- 3Pilot
Evaluate WayForge in a controlled deployment ahead of wider operational use.
Solution datasheet
Download the WayForge Datasheet
A concise technical overview of WayForge: capabilities, use cases, integration and deployment. Fill in your details and the datasheet unlocks immediately.
- Technical capability summary
- Operational use cases and deployment context
- Integration and ecosystem overview
- PDF, free to download
Discuss WayForge
Plan, task and deploy uncrewed systems through a consistent operational workflow.
Speak to Espanaro about a WayForge mission-planning workshop, platform integration assessment or pilot deployment.